Coin Picker Robot
.jpg)
Coin Picker Robot
As part of coursework, we made a remote controlled coin picking robot from a EFM8 (robot) and STM32 (remote) capable of moving around and picking up coins.
This robot includes:
- Firmware written in C
- Two JDY-40 wireless radios for wireless remote control. Each radio sends or recieves basic letters, which then represents a specific instruction dictated by the code.
- Two H-bridges, enabling directional control for two simple DC motors
- A colpitts oscillator for coin detection. The frequency emitted by the oscillator changes in response to magnetic interference, which allows the robot to detect metal objects such as coins.
- A double jointed servo arm and electromagnet for picking up coins and collecting them in an onboard container.
- An autonomous mode, which enables the robot to move around, detect and pick up coins without human input.
- A Manual mode, which allows a human to control the robot through a joystick and buttons.
Hardware Block Diagram
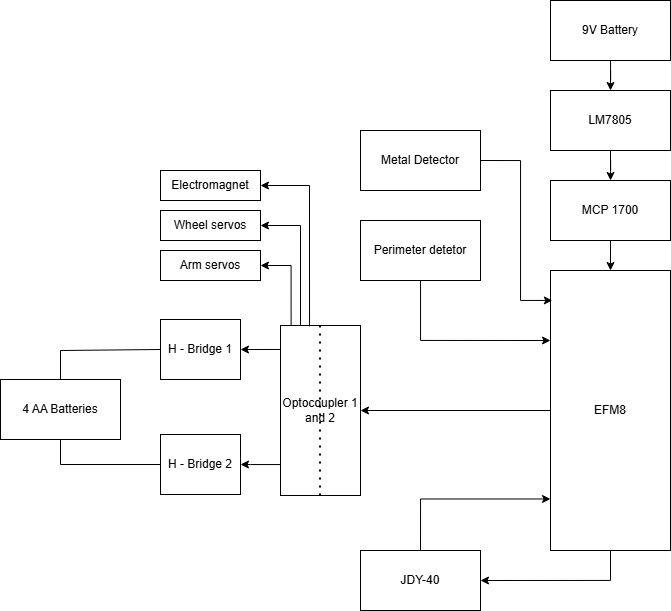 Figure: Block diagram of the coin picking robot hardware.
Software Block Diagram
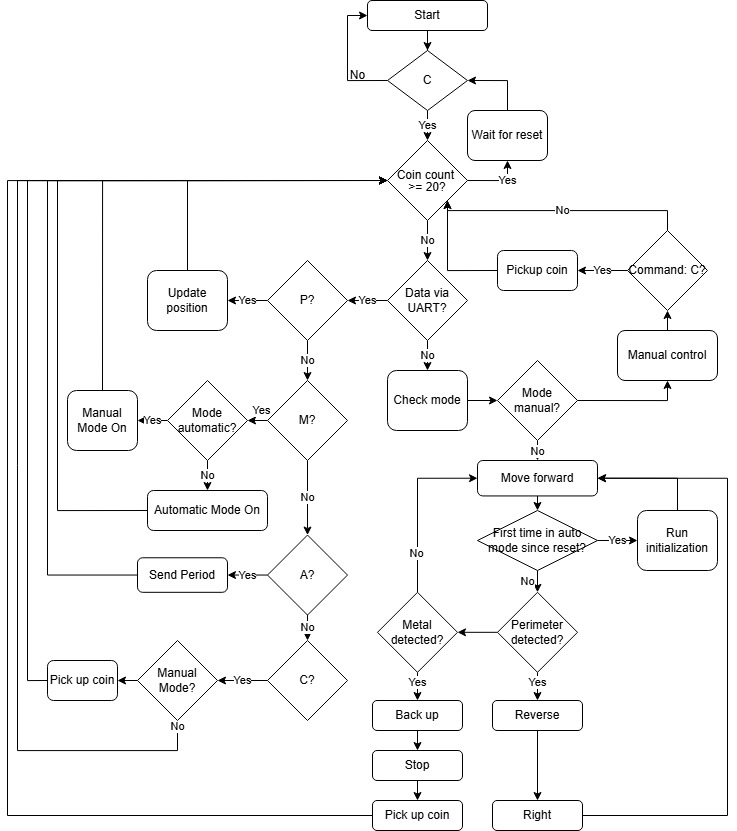 Figure: Block diagram of the coin picking robot software.
This post is licensed under CC BY 4.0 by the author.